Tommoro Partnership
Exclusively available in Korea through Tommoro Robotics.
20
ACTIVE DOF
1000 Hz
CONTROL RATE
≥12 N
FINGERTIP FORCE
CORE TECHNOLOGY
Four pillars of dexterity.
01
Biomimetic flesh and bone
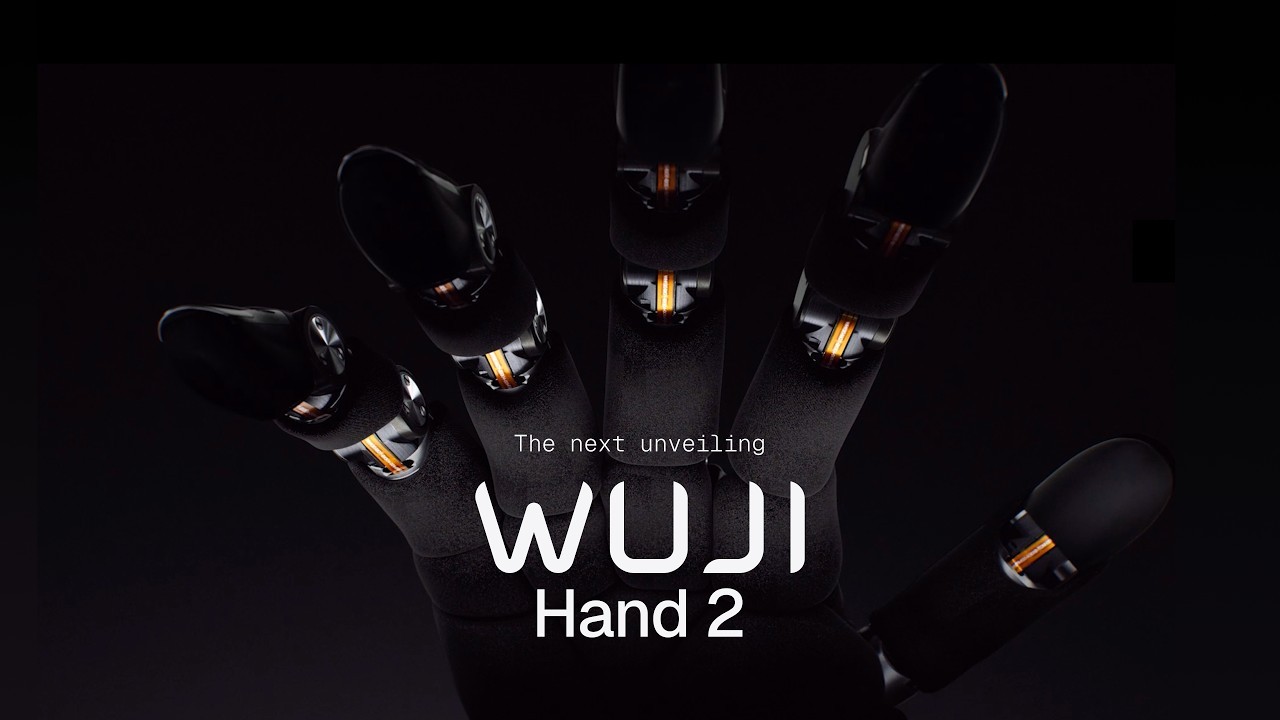
A skeleton and soft body modeled on the human hand.
02
Direct actuation, force penetration
Serial direct-drive joints - back-drivable, no kinematic coupling.
03
Touch aligned, fingers refined
Multi-axis force and torque sensing at every fingertip.
04
Compact size, mighty force
180 × 80 × 40 mm. Over 12 N at the fingertip, 1000 Hz on every axis.
IN MOTION
Yield over strength. Stand over time.
DEXTERITY

Twenty joints.
Direct drive.
Every joint is driven directly - no tendons, no coupling - so the hand yields under load and returns with less than a degree of backlash.
01
Serial direct-drive rotary joints - 4 per finger, 20 in total
02
Back-drivable, with no kinematic coupling between joints
03
MIT force-position hybrid control at 1000 Hz on every axis
TELEOPERATION

Hand to hand.
Wuji Glove captures tactile pressure and full-DoF pose from a human hand and retargets it to Wuji Hand 2 in real time - for teleoperation and data collection.
01
24 × 32 pressure matrix - 528 tactile points at 120 FPS
02
Five EMF modules track full-DoF pose at 120 Hz
03
Wuji Retargeting maps the glove onto the hand in real time
ECOSYSTEM
An all-in-one stack.
Wuji SDK & CLI
Unified device access, real-time visualization and one-stop debugging.
ROS 2
Native support for seamless integration with robotic systems.
MuJoCo · Isaac Sim
URDF, MJCF and USD models for high-fidelity sim-to-real training.
Teleop
Wuji Glove and other input devices, supported out of the box.
SPECIFICATIONS
Main specifications.
Active DoF
20 - 4 per finger
Kinematics
Direct-drive rotary, back-drivable
Fingertip force
≥12 N peak
Control
1000 Hz × 20 axes, MIT force-position hybrid
Dimensions
≈ 180 × 80 × 40 mm
Weight
800 g - 650 g bare hand
Interface
Ethernet, 100BASE-TX
Power
12 V DC